Posted 13 October 2026
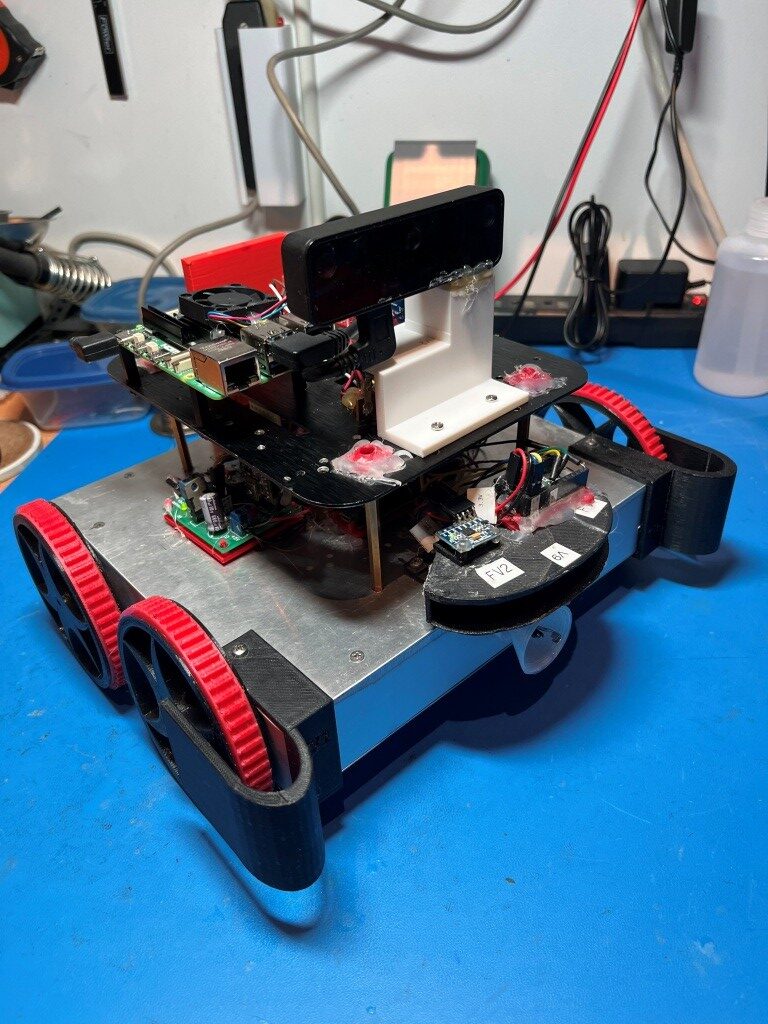
While working on my new ‘vision-enhanced’ robot project, it became apparent the the OAK-D Lite camera was not the best tool for handling a ‘stuck’ condition where the robot has nosed into something and needs to find a better movement direction. The camera After some experimentation, I found that by moving the rear-facing VL53L1X LIDAR distance sensor to the front of the robot, I could turn the robot under manual (‘C’) control and watch the reported LIDAR distances change. Since I had already solved the ‘Find Best Direction’ problem on my older robot, I decided to port the code into the new vision-enhanced robot.
Looking back through my old code in C:\Users\Frank\Documents\Arduino\WallE3_Git\WallE3_Git\WallE3_Git.ino, I found a reference to this post. It wasn’t directly relevant as it discussed the problem of sorting multiple arrays in a synchronized fashion so as to arrive at a situation where all the distance and heading sensor arrays are sorted in lockstep with a ‘master’ array containing front distance readings. Then the ‘dependent’ array readings associated with the maximum front distance reading can be easily read off.
This isn’t really necessary for the vision-enhanced robot, as there are only two sensors of interest – the front distances and the associated headings. I believe I should be able to set up two small lists (say 10 elements; front distance readings and associated headings. As the robot rotates, each new distance reading is compared to the stored ones, and replaces the largest value that is smaller than it. The headings array value associated with the replaced heading value gets replaced by the heading value associated with the new distance value. At the end of the rotation, the distance array should contain the 10 highest distance readings, sorted in descending order, and the heading array should be synchronized to their associated distances. Then an ‘appropriate’ heading can be selected from the data (‘appropriate’ to be defined later).
It turns out UpdateIMUHdgValDeg() already manages a HEADING_HISTORY_ARRAY_SIZE array of heading values, where earlier values are bumped up (down in index) and the latest value is stored at gl_HdgHistoryArray[HEADING_HISTORY_ARRAY_SIZE – 1]. If I also have a HEADING_HISTORY_ARRAY_SIZE array of distance values that are handled in the same manner, that should be all I need. I’m pretty sure I already have that array, as that is what is used to calculate variances needed to detect ‘stuck’ conditions. Yep – its there but named ‘aRearDistCM’ instead of ‘aFrontDistCM’. I’ll let that ride until everything is working and then change ‘Rear’ to ‘Front’ everywhere. CalcBruteRearDistArrayVariance() is also there for stuck detection. bool IsStuckBehind() is missing so copied it from WallE3_Git.ino to VisionEnhancedRobot…’. ino (into MISCELLANEOUS section).
Looking back through the code and previous posts, I built up the ‘QuickSort’ algorithms to handle just this situation, so abandoning them for something simpler does not seem real smart; it’s already there, and it works.
Well, maybe not. Looking at WallE3_Git.ino, I see that the RunToDaylight() code does not appear to use QuickSort at all – it does the ‘simpler’ idea of rotating 10 deg at a time, recording both heading and distance. After the rotation I see:
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 |
//if we get to here, no anomalies were detected //now find the largest distance recorded, and the associated heading uint16_t newhighdist = 0; float newhighhdgdeg = 0; for (size_t i = 0; i < RTMD_ARRAY_SIZE; i++) { if (FrontDistCm[i] > newhighdist) { gl_pSerPort->printf("Idx/Hdg/FrontD = %d/%2.1f/%d\n", i, HdgArrayDeg[i], FrontDistCm[i]); newhighdist = FrontDistCm[i]; newhighhdgdeg = HdgArrayDeg[i]; } } //at this point newhighdist holds highest distance from sweep, and newhighhdgdeg holds the heading assoc with that dist gl_pSerPort->printf("RotateToMaxDistance: highdist = %d, highhdg = %2.1f\n", newhighdist, newhighhdgdeg); TurnToHdgDeg(newhighhdgdeg); |
which is pretty much exactly the ‘simpler’ idea I was thinking about.
Well, I may have spoken too soon. WallE3_Git.ino has *two* ‘RunToDaylight()’ functions, ‘RunToDaylight()’ and ‘RunToDaylightV2()’, and ‘RunToDaylight()’ is apparently never called and was replaced by ‘RunToDaylightV2()’ which incorporates the QuickSort algorithms. However, only RunToDaylightV2() Step5:
|
1 2 3 |
//Step5: If no trackable wall is found, turn to the heading value that corresponds to the central element // of the first(only) group of front distance values > MIN_RUN_TO_DAYLIGHT_DIST_CM, and return with // WallTrackingCases TRACKING_NEITHER |
applies to this situation – all the other code is aimed at finding a trackable wall. Step5 is basically ‘RunToDaylight()’ with the distance and heading arrays presorted by decreasing distance with
|
1 |
QuickSortAll(false, FrontD, Hdg, LeftD, LeftSteer, RightD, RightSteer, 0, QUICKSORT_ARRAY_SIZE - 1); |
I made the decision to port all the ‘RunToDaylightV2()’ and supporting code to the new ‘stuck-recovery’ branch, trimmed down to just the ‘Hdg’ and ‘FrontD’ arrays for now (may later want to add RearD, but not now). This is basically just the ‘Step5’ portion of ‘RunToDaylightV2()’, with the addition of all the supporting code for QuickSort operations.
I have the ‘stuck ahead’ detection running now. Here’s a sample output:
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 |
Time BattV TopI BotI ChgI FrontCm FrontVar Hdg Lspd Rspd 9644 8.11 0.45 0.01 0.40 406.60 49148.18 0.07 0 0 10678 8.12 0.45 0.01 0.41 414.10 37536.78 0.09 0 0 11645 8.11 0.41 0.00 0.41 403.10 40442.10 0.12 0 0 12643 8.11 0.44 0.00 0.42 425.30 41701.23 0.15 0 0 13674 8.11 0.40 0.00 0.41 423.30 20153.20 0.18 0 0 14641 8.10 0.40 0.00 0.41 422.20 322.83 0.21 0 0 15712 8.11 0.42 0.00 0.41 0.60 5123.27 0.24 0 0 16736 8.11 0.42 0.00 0.41 0.00 20043.77 0.27 0 0 17759 8.11 0.44 0.00 0.41 0.00 31153.34 0.31 0 0 18693 8.10 0.45 0.01 0.41 0.00 37684.86 0.34 0 0 19716 8.11 0.42 0.00 0.42 0.00 40898.73 0.37 0 0 20748 8.11 0.43 0.01 0.41 0.00 40524.75 0.40 0 0 21674 8.10 0.44 0.00 0.41 0.00 36600.52 0.42 0 0 22695 8.12 0.40 0.00 0.41 0.00 28881.70 0.43 0 0 23729 8.12 0.46 0.00 0.41 0.00 16428.35 0.43 0 0 24752 8.12 0.44 0.01 0.41 0.00 0.00 0.43 0 0 Stuck Ahead Detected at 24836: gl_FrontCm = 0.1, FrontVar = 0.0 |
The next step is to use the ‘RunToDaylightV2()’ function and supporting QuickSort code to determine the best direction to travel *after* IsStuck() returns TRUE.
18 October 2026 Update:
After getting the stuck-recovery code working, I created a new C++ project on my PC to parse through the output generated by the 360 degree scans from ‘stuck-recovery’. Here’s the final code:
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 31 32 33 34 35 36 37 38 39 40 41 42 43 44 45 46 47 48 49 50 51 52 53 54 55 56 57 58 59 60 61 62 63 64 65 66 67 68 69 70 71 72 73 74 75 76 77 78 79 80 81 82 83 84 85 86 87 88 89 90 91 92 93 94 95 96 97 98 99 100 101 102 103 104 105 106 107 108 109 110 111 112 113 114 115 116 117 118 119 120 121 122 123 124 125 126 127 128 129 130 131 132 133 134 135 136 137 138 139 140 141 142 143 144 145 146 147 148 149 150 151 152 153 154 155 156 157 158 159 160 161 162 163 164 165 166 167 168 169 170 171 172 173 174 175 176 177 178 179 180 181 182 183 184 185 186 187 188 189 190 191 192 193 194 195 196 197 198 199 200 201 202 203 204 205 206 207 208 209 210 211 212 213 214 215 216 217 218 219 220 221 222 223 224 225 226 227 228 229 230 231 232 233 234 235 236 237 238 239 240 241 242 243 244 245 246 247 248 249 250 251 252 253 254 255 256 257 258 259 260 261 262 263 264 265 266 267 268 269 270 271 272 273 274 275 276 277 278 279 280 281 282 283 284 285 286 287 288 289 290 291 292 293 294 295 296 297 298 299 300 301 302 303 304 305 306 307 308 309 310 311 312 313 314 315 316 317 318 319 320 321 322 323 324 325 326 327 328 329 330 331 332 333 334 335 336 337 338 339 340 341 342 343 344 345 346 347 348 349 350 351 352 353 354 355 356 357 358 359 |
// QuickSortV3.cpp : This file contains the 'main' function. Program execution begins and ends there. // /*Quicksort Test program The idea is to determine whether or not I can sort multiple associated arrays by sorting a 'master' array (say front distances) and having other arrays be sorted using the same sort index sequence as the master array. Master (front distance) FrontD: int FrontD[] = { 219, 30, 114, 152, 41, 86 }; Slave (Heading) array: float Hdg[] = { 19, 3, 11, 15, 4, 8 }; */ #include <iostream> #include <sstream> #include <string> #include <vector> using namespace std; //int FrontD[] = { 9, 3, 4, 2, 1, 8 }; ////real measurement data //float FrontD[] = { 121.6, 124.1, 146.4, 114.2, 67.6, 59.9, 48.4, 44.2, 35.3, 37.9, 40.1, 42.8, 46.3, 52.4, 59.5, 93.0, 91.3, 85.5, 101.9, 229.0, 260.7, 312.9, 388.1, 414.6, 347.8, 58.1, 51.5, 54.8, 59.5, 75.7, 98.1, 38.3, 121.5, 114.5, 130.8, 138.5 }; //float Hdg[] = { 0.0, 9.4, 18.7, 28.5, 39.1, 49.2, 59.1, 69.2, 78.8, 88.4, 99.0, 109.0, 118.5, 128.3, 138.1, 154.9, 164.7, 174.2, -176.3, -160.3, -149.0, -138.9, -129.9, -118.0, -106.8, -96.8, -87.3, -77.5, -67.9, -58.1, -47.7, -37.4, -28.0, -18.2, -8.7, 1.1 }; std::vector<float> FrontD; std::vector<float> Hdg; //new plan; convert the arrays from the tabular form as they come off the generating program into the comma-delimited arrays as shown above //const char* rawScan = R"( //MSec FrontD Hdg //8717 106.0 0.0 //8979 427.9 6.1 //9179 79.4 10.2 //9443 57.6 16.4 //9707 58.0 22.6 //9914 61.6 26.5 //10177 62.5 33.0 //10441 67.7 39.2 //10650 77.5 43.6 //10913 85.0 49.9 //11177 138.8 56.4 //11321 123.8 60.2 //11585 134.4 66.7 //11847 134.8 72.4 //12056 133.9 76.4 //12319 128.8 82.2 //12528 124.3 86.5 //12791 143.5 92.5 //12991 148.4 96.4 //13255 148.8 102.3 //13399 145.0 106.5 //13661 118.6 112.8 //13870 77.6 116.6 //14133 70.7 122.5 //14277 62.9 126.7 //14541 60.7 133.0 //14685 52.5 136.9 //14949 48.2 143.4 //15213 44.5 149.5 //15595 37.3 160.1 //15859 35.5 165.8 //16123 36.3 171.4 //16332 38.9 175.2 //16596 38.8 -179.4 //16859 38.6 -173.8 //17123 40.2 -167.7 //17330 42.8 -163.7 //17593 43.2 -157.8 //17857 46.0 -152.1 //18121 49.9 -146.2 //18385 55.4 -140.1 //18585 61.1 -136.2 //18849 68.1 -129.9 //19113 78.3 -124.0 //19320 90.2 -119.2 //19583 89.3 -113.4 //19792 86.0 -109.1 //20055 84.2 -102.9 //20255 84.2 -98.8 //20519 89.2 -93.2 //20783 205.2 -87.2 //20927 225.2 -83.2 //21189 224.6 -77.8 //21453 237.6 -71.5 //21542 251.6 -67.2 //21805 276.1 -61.3 //21949 284.7 -57.2 //22213 321.4 -50.9 //22413 362.0 -47.0 //22677 396.5 -40.7 //22877 395.9 -36.7 //23139 395.1 -30.7 //23403 353.2 -25.2 //23612 262.6 -21.1 //23875 395.7 -15.0 //24139 50.5 -8.9 //24403 46.9 -2.8 //24667 47.5 3.2 //24874 50.3 7.2 //25137 52.1 13.3 //25401 57.3 19.2 //25610 62.9 23.2 // //)"; const char* rawScan = R"( MSec FrontD Hdg 8632 408.9 0.0 8894 433.5 - 7.1 9038 367.9 - 11.0 9238 381.3 - 14.7 9438 386.8 - 18.5 9702 366.9 - 24.7 9964 340.4 - 30.6 10173 304.5 - 34.8 10436 286.4 - 40.8 10645 266.9 - 44.9 10908 262.1 - 51.3 11172 233.7 - 57.6 11372 225.6 - 61.7 11636 163.5 - 68.6 11843 87.8 - 72.9 12106 85.9 - 79.1 12315 86.2 - 83.3 12578 89.7 - 89.9 12722 91.3 - 94.4 12922 91.2 - 98.1 13122 83.4 - 102.5 13322 70.8 - 106.3 13586 63.7 - 112.9 13673 60.1 - 117.0 13881 51.5 - 121.0 14024 48.0 - 125.1 14233 47.6 - 129.1 14376 42.9 - 132.8 14576 42.1 - 137.0 14776 38.5 - 141.0 15040 37.1 - 147.9 15240 35.3 - 151.7 15504 34.7 - 158.7 15648 29.8 - 162.9 15855 29.9 - 166.6 15943 29.9 - 170.9 16151 33.8 - 174.7 16414 35.2 180.0 16678 36.9 174.2 16942 38.2 168.1 17142 41.7 163.9 17406 42.9 157.2 17733 50.1 150.7 17876 54.3 146.6 18140 58.9 140.1 18404 73.2 133.9 18604 115.9 129.9 18868 135.9 123.7 19068 140.8 119.5 19332 139.3 113.3 19539 129.8 108.9 19802 111.7 102.3 19891 114.4 98.2 20099 113.3 93.8 20178 126.3 89.8 20387 142.0 85.6 20530 126.3 81.3 20730 31.2 77.3 20874 27.9 72.8 21194 81.5 62.8 21401 76.0 58.6 21544 70.9 54.5 21808 67.4 47.3 21952 61.0 43.1 22161 60.6 39.2 22304 60.0 34.8 22504 57.9 31.0 22704 61.2 26.7 22904 68.7 23.0 23168 417.9 16.9 23375 410.2 12.7 23638 341.2 6.7 )"; //int n = 36; //#define NUM_SAMPLES 36 int n = 72; #define NUM_SAMPLES 72 int THRESHOLD = 200; struct RunItem { float Hdg = 0; float Dist = 0; }; int bestStart = -1, bestEnd = -1; float bestWidth = 0; int numruns = 0; int runStart = -1; RunItem samples[NUM_SAMPLES]; // or 72 void ParseScan() { std::istringstream iss(rawScan); std::string line; while (std::getline(iss, line)) { if (line.empty() || line.find("FrontD") != std::string::npos) continue; // normalize whitespace and the spaced minus that paste sometimes inserts for (char& c : line) if (c == '\t') c = ' '; size_t pos; while ((pos = line.find(" - ")) != std::string::npos) line.replace(pos, 3, "-"); while ((pos = line.find(" -")) != std::string::npos) line.replace(pos, 2, "-"); std::istringstream row(line); float msec, dist, hdg; if (row >> msec >> dist >> hdg) { FrontD.push_back(dist); Hdg.push_back(hdg); } } cout << "FrontD has " << FrontD.size() << " elements\n"; } void TerminateRun(int i) { // run ended at i-1 float width = samples[i - 1].Hdg - samples[runStart].Hdg; //watch out for 'fold' width results > 180 or < -180 if (width > 180) { width -= 360; } else if (width < -180) { width += 360; } width = abs(width); if (width > bestWidth) { bestWidth = width; bestStart = runStart; bestEnd = i - 1; } runStart = -1; numruns++; } // fill samples[] during the scan (or copy from your existing arrays) void GetBestDistance() { //Purpose: Determine 'Best Distance' from a set of NUM_SAMPLES Hdg/Dist pairs //Inputs: // Fixed set of real samples in FrontD[NUMSAMPLES] and Hdg[NUMSAMPLES] synchronized arrays //Outputs: // bestWidth = width (in deg) of the largest contiguous run of FrontD measurements // bestStart, bestEnd = start & end idices for the 'bestWidth' run //Plan: // Step1: fill samples[] during the scan (or copy from your existing arrays) // Step2: work through entire Hdg/Dist sample items looking for contiguous runs (can be just one item) // for each such run, calc bestWidth, bestStart, bestEnd. If 'bestWidth' is greater than all // previous runs detected, replace the old bestWidth, bestStart, bestEnd values // Step3: If there are multiple 'far' runs, check to if two of them can be stitched // together around the +/- 0 degree fold. //Step1: fill samples[] during the scan (or copy from your existing arrays) ParseScan(); //Step2: work through entire Hdg/Dist sample items looking for contiguous runs (can be just one item) // for each such run, calc bestWidth, bestStart, bestEnd. If 'bestWidth' is greater than all // previous runs detected, replace the old bestWidth, bestStart, bestEnd values for (int i = 0; i < NUM_SAMPLES; i++) { samples[i].Dist = FrontD[i]; samples[i].Hdg = Hdg[i]; //print out for debug cout << "samples[" << i << "] = (" << samples[i].Dist << ", " << samples[i].Hdg << ")\n"; } for (int i = 0; i < NUM_SAMPLES; i++) { if (samples[i].Dist >= THRESHOLD) { if (runStart < 0) { runStart = i; } // don’t forget to close a run that reaches the end of the array //terminate this run if we run out of samples if (i >= NUM_SAMPLES-1) { TerminateRun(i); } // start a new run // else just keep extending } //this doesn't execute unless samples[i] < THRESHOLD else if (runStart >= 0 ) { TerminateRun(i); } } //Step3: If there are multiple 'far' runs, check to if two of them can be stitched // together around the +/- 0 degree fold. if (samples[0].Dist >= THRESHOLD && samples[NUM_SAMPLES - 1].Dist >= THRESHOLD) { // find how far the opening extends from each end int endRun = NUM_SAMPLES - 1; while (endRun > 0 && samples[endRun].Dist >= THRESHOLD) endRun--; endRun++; // first index of the trailing far run int startRun = 0; while (startRun < NUM_SAMPLES - 1 && samples[startRun].Dist >= THRESHOLD) startRun++; startRun--; // last index of the leading far run // angular width across the fold float width = samples[startRun].Hdg - samples[endRun].Hdg; if (width > 180) width -= 360; if (width < -180) width += 360; width = fabs(width); if (width > bestWidth) { bestWidth = width; bestStart = endRun; bestEnd = startRun; numruns--; // the two fragments are now one physical run } } cout << "numruns = " << numruns << ", bestwidth = " << bestWidth << ", bestStart = " << bestStart << ", bestEnd = " << bestEnd; return; } int main() { GetBestDistance();//added 10/17/26 to isolate new code return 0; } |
Including both 36-point (10 deg steps) and a 72-point (5 deg steps) datasets from the ‘stuck-recovery’ code. With the 72-point (5 deg steps) scan data active, the .cpp program produces the following output.
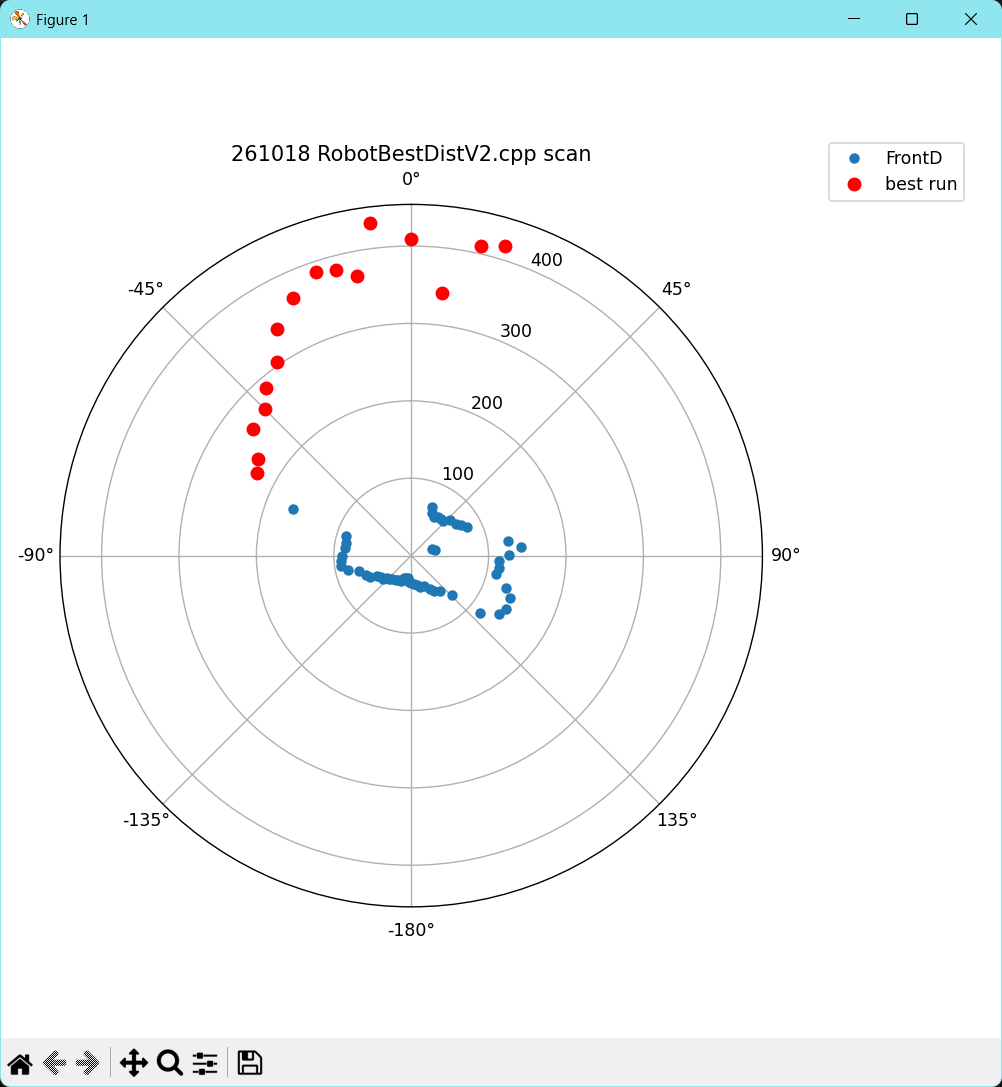
The above plot was generated using a small Python program generated by Grok, as shown below:
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 31 32 33 34 35 36 37 38 39 40 41 42 43 44 45 46 47 48 49 50 51 52 53 54 55 56 57 58 59 60 61 62 63 64 65 66 67 68 69 70 71 72 73 74 75 76 77 78 79 80 81 82 83 84 85 86 87 88 89 90 91 92 93 94 95 96 97 98 99 100 101 102 103 104 105 106 107 108 109 110 111 112 113 114 115 116 117 118 119 120 121 122 123 124 125 126 127 128 129 130 131 132 133 134 135 136 137 138 139 140 141 |
#!/usr/bin/env python3 """ Polar plot of a WallE RunToDaylight scan. Paste the raw table (either spaced-minus or tab-delimited) between the triple quotes. Points are sorted by heading so the connecting line follows angular order and wrap-around lobes display correctly. """ import re import numpy as np import matplotlib.pyplot as plt raw = """ MSec FrontD Hdg 8632 408.9 0.0 8894 433.5 - 7.1 9038 367.9 - 11.0 9238 381.3 - 14.7 9438 386.8 - 18.5 9702 366.9 - 24.7 9964 340.4 - 30.6 10173 304.5 - 34.8 10436 286.4 - 40.8 10645 266.9 - 44.9 10908 262.1 - 51.3 11172 233.7 - 57.6 11372 225.6 - 61.7 11636 163.5 - 68.6 11843 87.8 - 72.9 12106 85.9 - 79.1 12315 86.2 - 83.3 12578 89.7 - 89.9 12722 91.3 - 94.4 12922 91.2 - 98.1 13122 83.4 - 102.5 13322 70.8 - 106.3 13586 63.7 - 112.9 13673 60.1 - 117.0 13881 51.5 - 121.0 14024 48.0 - 125.1 14233 47.6 - 129.1 14376 42.9 - 132.8 14576 42.1 - 137.0 14776 38.5 - 141.0 15040 37.1 - 147.9 15240 35.3 - 151.7 15504 34.7 - 158.7 15648 29.8 - 162.9 15855 29.9 - 166.6 15943 29.9 - 170.9 16151 33.8 - 174.7 16414 35.2 180.0 16678 36.9 174.2 16942 38.2 168.1 17142 41.7 163.9 17406 42.9 157.2 17733 50.1 150.7 17876 54.3 146.6 18140 58.9 140.1 18404 73.2 133.9 18604 115.9 129.9 18868 135.9 123.7 19068 140.8 119.5 19332 139.3 113.3 19539 129.8 108.9 19802 111.7 102.3 19891 114.4 98.2 20099 113.3 93.8 20178 126.3 89.8 20387 142.0 85.6 20530 126.3 81.3 20730 31.2 77.3 20874 27.9 72.8 21194 81.5 62.8 21401 76.0 58.6 21544 70.9 54.5 21808 67.4 47.3 21952 61.0 43.1 22161 60.6 39.2 22304 60.0 34.8 22504 57.9 31.0 22704 61.2 26.7 22904 68.7 23.0 23168 417.9 16.9 23375 410.2 12.7 23638 341.2 6.7 """ # --- parse ----------------------------------------------------------------- rows = [] for line in raw.strip().splitlines(): line = line.strip() if not line or "FrontD" in line: continue # pull out every number (optional minus, digits, optional decimal) nums = re.findall(r"-?\d+\.?\d*", line.replace(" - ", " -")) if len(nums) >= 3: dist = float(nums[1]) hdg = float(nums[2]) rows.append((hdg, dist)) else: print("SHORT:", repr(line)) hdg = np.array([r[0] for r in rows]) dist = np.array([r[1] for r in rows]) print(f"Parsed {len(rows)} samples") print("Heading range:", hdg.min(), "to", hdg.max()) # --- sort by heading so the line follows angular order --------------------- order = np.argsort(hdg) theta_sorted = np.deg2rad(hdg[order]) dist_sorted = dist[order] # --- debug: show how the headings sorted ---------------------------------- print("Sorted headings:") print(np.round(hdg[order], 1)) # --- polar plot (markers only first) --------------------------------------- fig = plt.figure(figsize=(8, 8)) ax = fig.add_subplot(111, projection="polar") ax.plot(theta_sorted, dist_sorted, "o", markersize=5, label="FrontD") # highlight winning sector win_idx = list(range(69, 72)) + list(range(0, 13)) if max(win_idx) < len(hdg): ax.plot(np.deg2rad(hdg[win_idx]), dist[win_idx], "o", color="red", markersize=7, label="best run") ax.set_theta_zero_location("N") ax.set_theta_direction(-1) # full circle, labels shown as -180..+180 tick_angles = np.arange(0, 360, 45) tick_labels = [f"{((a + 180) % 360) - 180}°" for a in tick_angles] ax.set_thetagrids(tick_angles, tick_labels) ax.set_title("261018 RobotBestDistV2.cpp scan") ax.legend(loc="upper right", bbox_to_anchor=(1.3, 1.1)) plt.tight_layout() plt.show() |
19 October 2026 Update:
Grok modified the ‘polar_scan.py’ script to pull the required ‘bestStart’ and ‘bestEnd’ values directly out of the raw data from the robot. With the following data
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 31 32 33 34 35 36 37 38 39 40 41 42 43 44 45 46 47 48 49 50 51 52 53 54 55 56 57 58 59 60 61 62 63 64 65 66 67 68 69 70 71 72 73 |
MSec FrontD Hdg 8650 353.8 0.1 8913 394.9 -6.8 9177 375.7 -13.0 9321 380.0 -16.7 9521 390.6 -20.4 9785 351.9 -26.7 9992 318.4 -31.1 10255 296.2 -37.0 10464 279.9 -40.8 10727 268.2 -46.5 10871 247.5 -50.4 11135 231.1 -57.0 11399 220.6 -63.4 11543 210.7 -67.4 11805 88.6 -73.7 12069 81.7 -80.1 12278 82.2 -84.6 12541 85.6 -91.2 12741 87.6 -95.1 13005 83.7 -101.8 13205 73.2 -105.9 13469 62.2 -112.6 13731 60.5 -119.1 13875 52.6 -123.1 14084 52.1 -127.0 14347 46.1 -133.4 14547 43.1 -137.6 14811 41.5 -143.9 15075 39.4 -150.0 15275 37.9 -154.1 15537 37.0 -160.3 15746 36.8 -164.2 16009 37.5 -170.6 16218 35.5 -175.0 16482 34.6 178.7 16745 41.6 172.7 16945 43.8 168.5 17209 46.6 162.1 17471 52.1 156.3 17680 57.2 151.9 17943 62.6 145.9 18152 69.1 141.8 18415 80.6 135.5 18615 114.4 131.3 18879 144.0 124.7 19079 147.2 120.7 19341 144.6 114.8 19550 135.4 111.0 19813 131.0 104.5 20022 133.4 100.4 20285 136.0 93.9 20485 145.3 89.7 20749 146.0 83.3 20893 139.5 79.6 21100 131.3 75.6 21308 134.3 71.6 21571 124.9 64.9 21835 73.2 58.5 21979 63.2 54.5 22179 62.5 50.5 22323 58.8 46.5 22523 58.3 42.7 22787 53.7 36.3 22994 47.0 32.4 23257 47.0 25.8 23466 21.7 21.9 23729 298.5 16.7 23993 408.9 11.1 24257 381.3 5.1 24457 384.8 1.2 24721 365.7 -5.1 24983 313.5 -11.2 |
The polar_scan.py program produced the following plot:
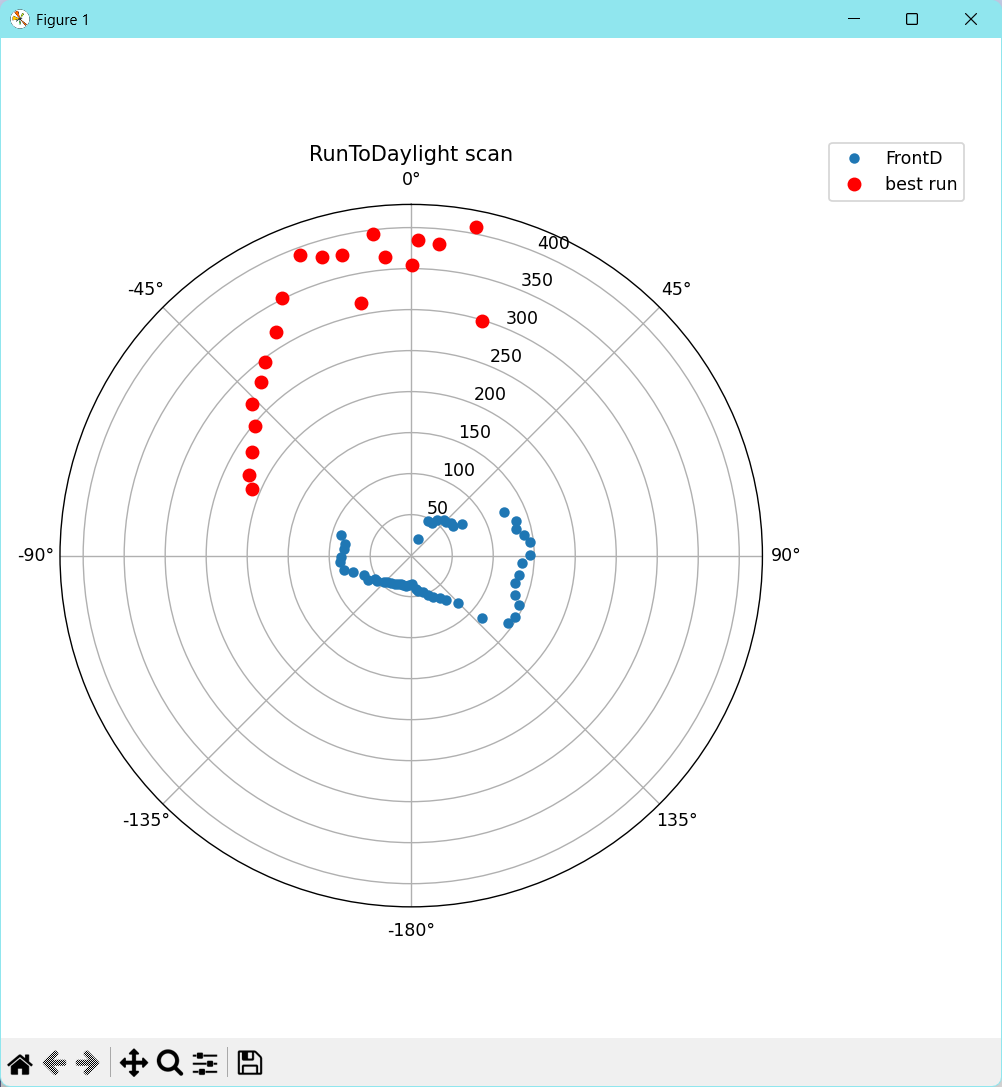
This is a bit of an unrealistic scenario, as I deliberately started the robot scan with its front toward the open doorway, in order to excite the edge case where the ‘best direction’ lobe crosses over the +/- 0 deg boundary. In reality the ‘best direction scan will almost certainly start with the robot pointed away from the ‘best’ direction, as that condition is what triggers the ‘run to daylight’
It is also unrealistic in another way, in that this data was collected with my robot sitting on my bench, with the robot’s VL53L1X distance sensor about 90cm off the ground. In reality it will be more like 17cm off the floor in real operation.
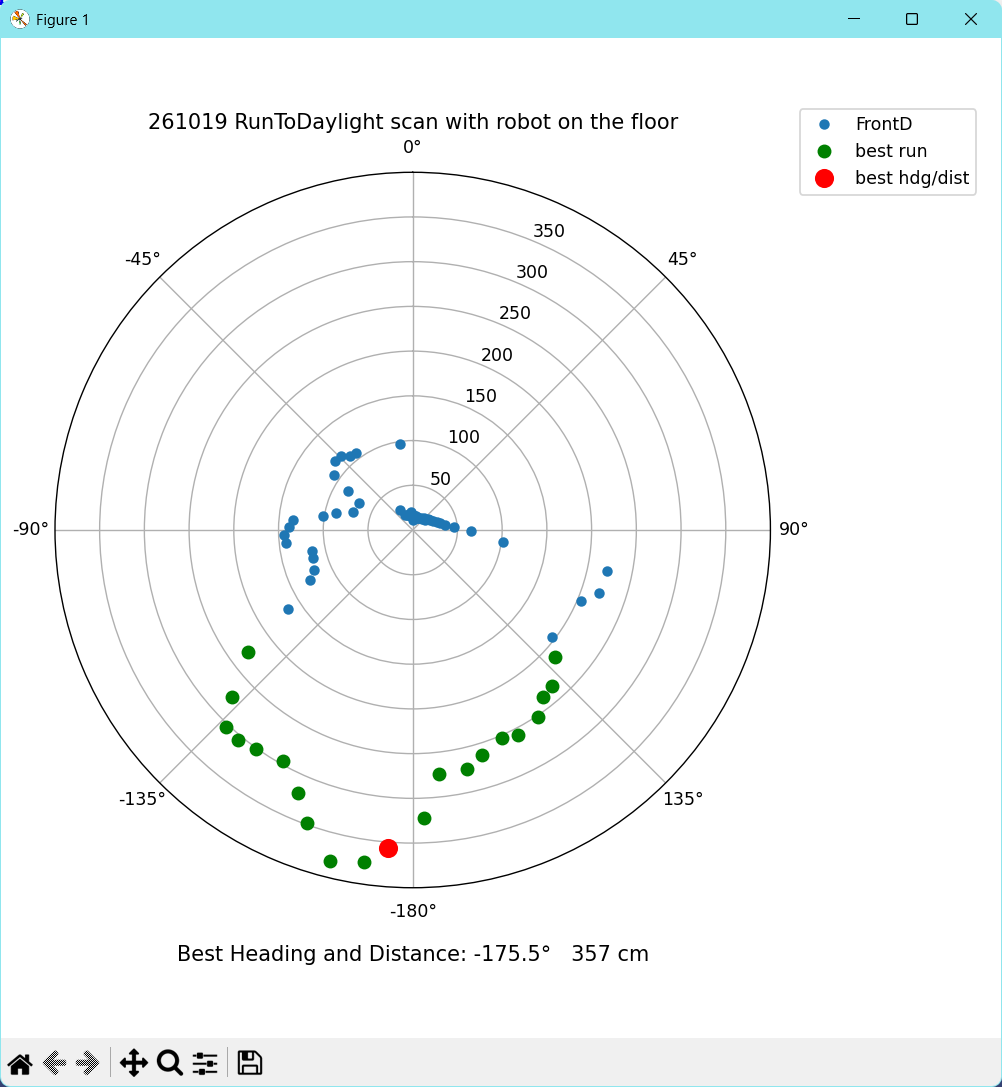
Here is the scan from the robot sitting on the floor, starting with its nose just a few centimeters away from a simulated wall, with the open area behind it.
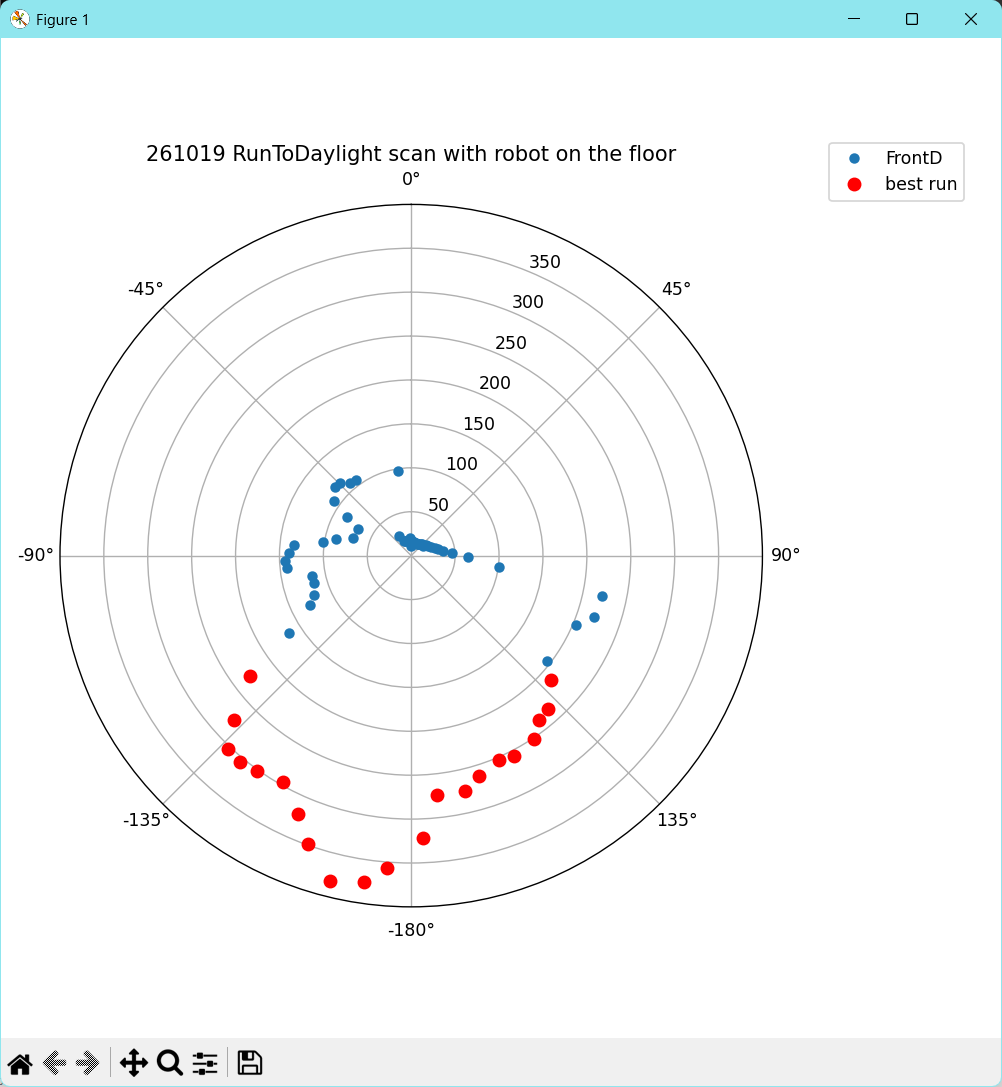
As the plot shows, there is a fairly wide of headings from about -135 to +135 deg, with the peak at about -170 or so. This corresponds very to the actual layout of my lab.
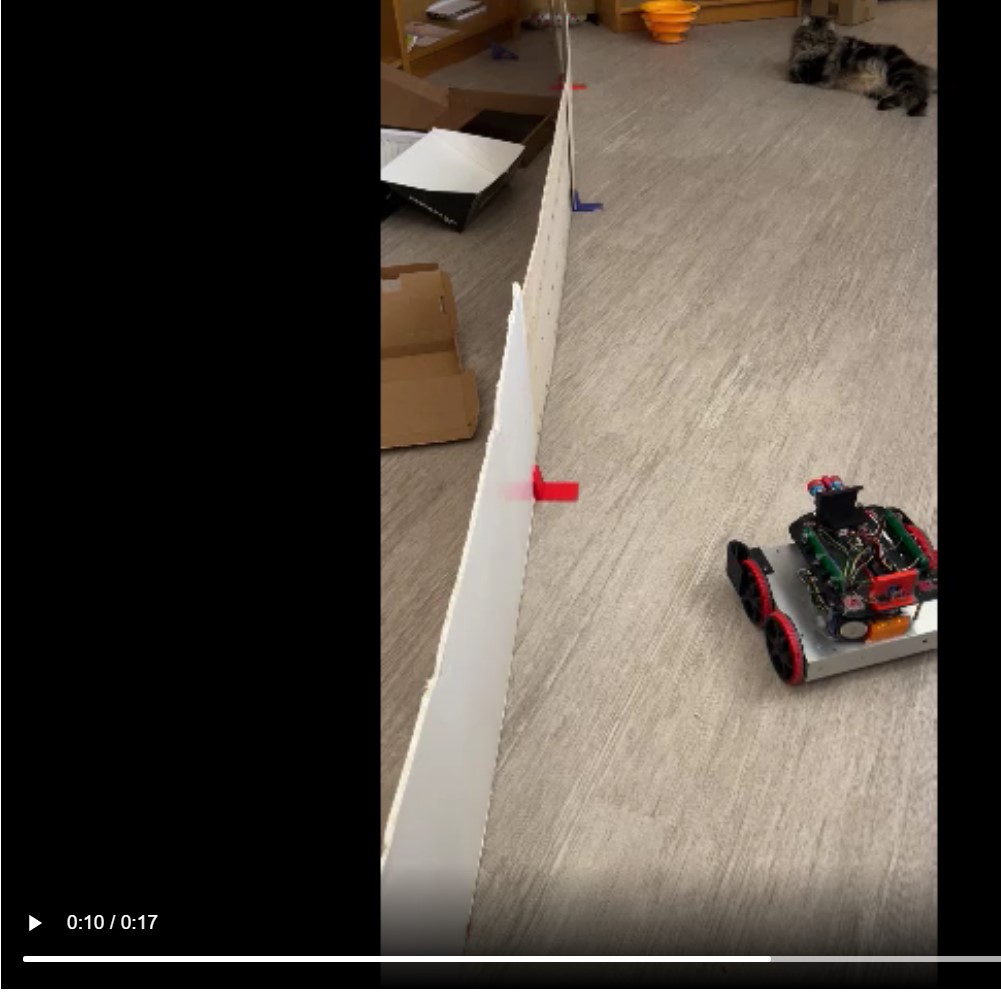
I attached my iPhone to the robot in the same place as the VL53L1X sensor and ran another 360 scan. The result was this video:
The far doorway can be seen in the video at about the 8 second mark.
20 October 2026 Update:
The ‘Find Best Direction’ study is complete. the ‘polar_scan.py’ script takes the scan data from the robot and produces the polar plot shown below:
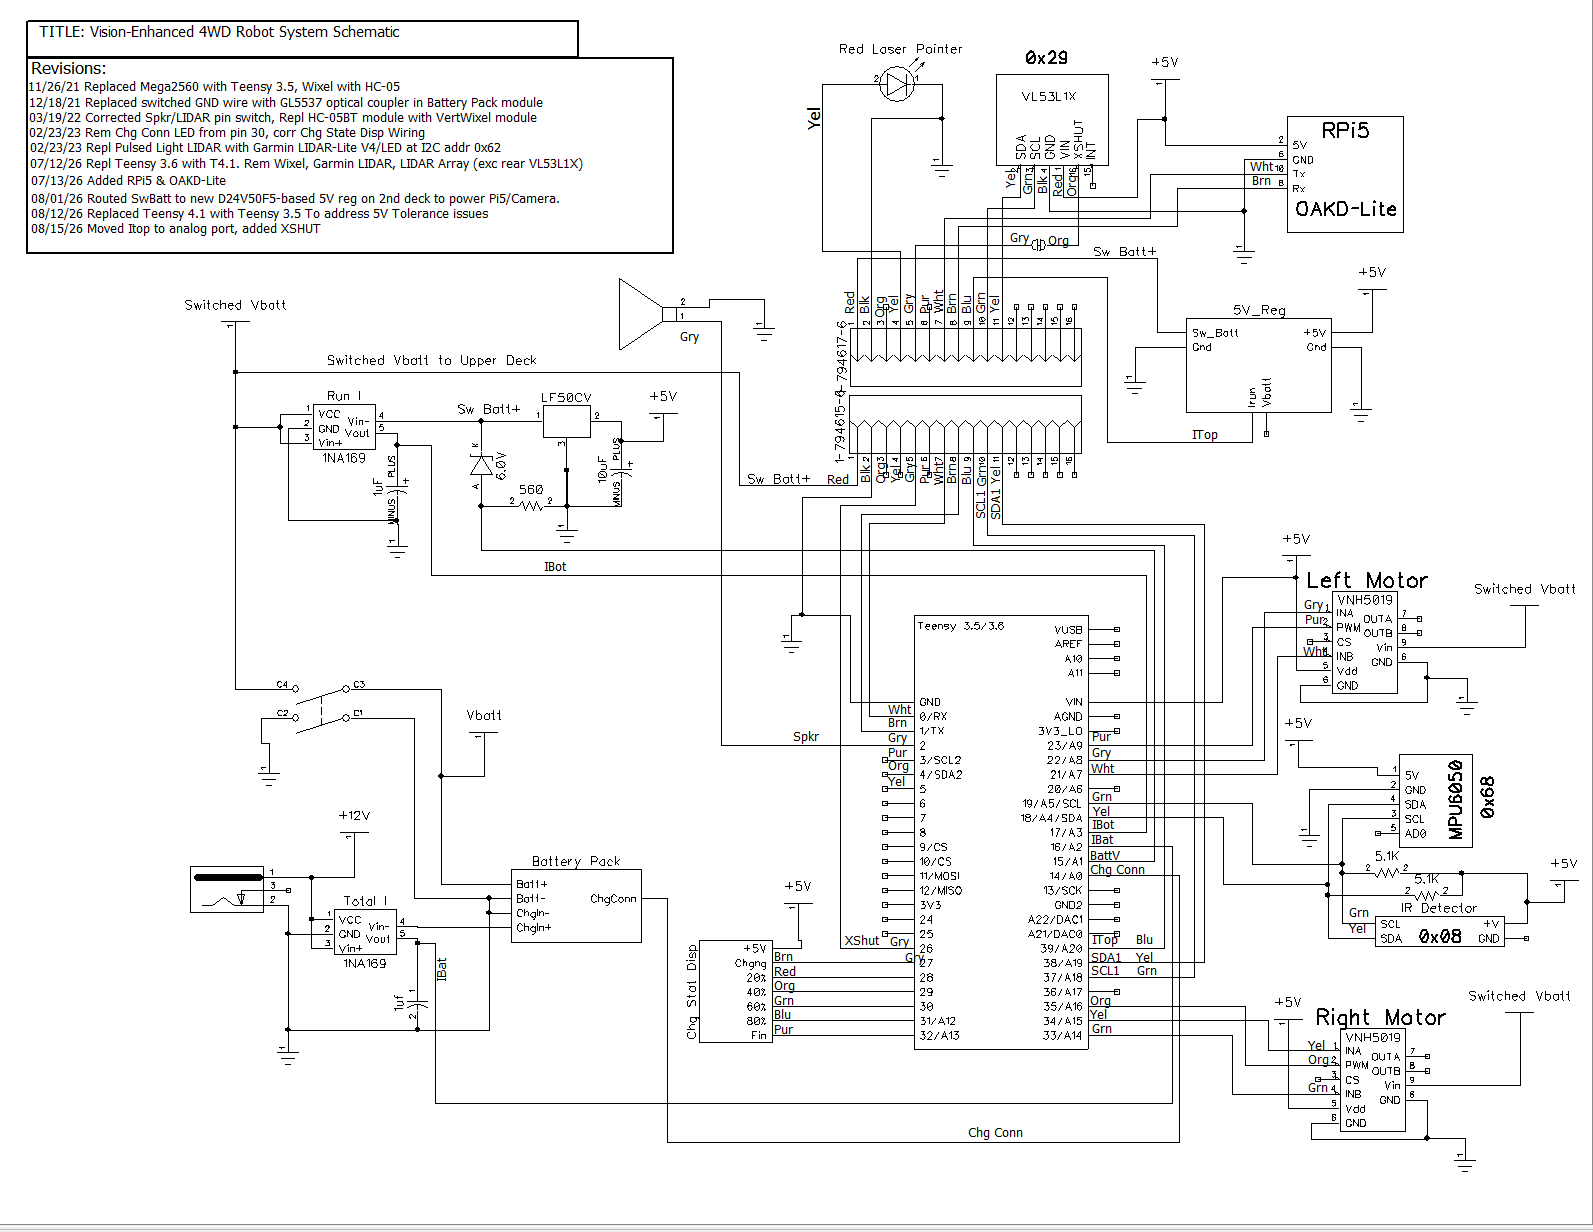
Now it’s time to integrate all this back into the mainline repo. I had a conversation with Grok about this, and I believe I am coming around to his/its way of thinking. Have the teensy handle initial ‘stuck’ detection using a variance threshold on the front-facing VL53L1X. If a stuck condition is detected, notify the Pi5. The Pi5 tells the teensy to back up 1 sec & perform a 360 deg scan and report distances and headings. The Pi5 will then run the above ‘polar_scan’ script to determine the best escape direction and tell the teensy to turn to that heading. After that the Pi5 uses the camera to validate the escape direction, and if it agrees, normal travel/navigation is resumed.
21 October 2026 Update:
I committed/pushed the ‘stuck-recovery’ branch from my PC – this is all the stuck-recovery scan code, but minus all the required integration code.
So, what to do about the big switch statement in CheckForUserInput? Right now it switches on the first character of the string. Some commands are truly single-character (C, H, U…) but some are single-alpha + numeric (Txx, Lxx, Rxx), where the ‘xx’ are arbitrary numeric characters. Now I want to add full-string commands like ‘STUCK_SCAN’, but this results in “Unknown top-level character”. I could add a ‘S’ case, but I might eventually run out of single-character commands. Maybe the way to handle this is with a ‘!’ (bang) prefix, which says “look at the full string”. A case statement like “case ‘!’: would handle all multi-alpha characters commands and would then use internal ‘if’ statements to accommodate an arbitrary number of commands
So, I started with “!STUCK_SCAN”. When this string is entered at the serial port, CheckForUserInput() runs this code:
|
1 2 3 4 5 6 7 8 9 10 |
case '!': gl_pSerPort->printf(F("%lu: 'In '!' case\n"), millis()); if (strncmp(buff, "!STUCK_SCAN", strlen("!STUCK_SCAN") == 0)) { gl_pSerPort->printf(F("%lu: 'stuck scan' request received\n"), millis()); StopBothMotors(); RunToDaylightV2(); retval = true; } break; |
It stops the motors and then calls RunToDaylightV2():
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 |
void RunToDaylightV2() { //Step1: rotate 360deg in 10deg steps, filling arrays with the corresponding values for (size_t i = 0; i < RUN_TO_DAYLIGHT_ARRAY_SIZE; i++) { //get current environmental variables UpdateAllEnvironmentParameters(); Hdg[i] = IMUHdgValDeg; FrontD[i] = gl_FrontCm; Msec[i] = millis(); SpinTurn(true, 360/ RUN_TO_DAYLIGHT_ARRAY_SIZE); } |
which repeatedly calls SpinTurn(true, 5) to scan 360 degrees.
This all works great – except – – – when RunToDaylightV2 is running a scan, it can’t be stopped – oops! The reason it can’t be stopped is because it isn’t calling CheckForUserInput() inside the ‘for’ loop. The obvious answer is to place a call to CheckForUserInput() inside the loop and then send a ‘C’ character to the teensy, which will stop the motors ….. except that it doesn’t; it stops the motors, but then the next call to SpinTurn() starts them up again – rats!
So, next we try using the bool return from CFUI() to guard the SpinTurn() calls, like so:
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 |
for (size_t i = 0; i < RUN_TO_DAYLIGHT_ARRAY_SIZE; i++) { //get current environmental variables UpdateAllEnvironmentParameters(); Hdg[i] = IMUHdgValDeg; FrontD[i] = gl_FrontCm; Msec[i] = millis(); //10 / 22 / 26 added line to check for user input between steps bool status = CheckForUserInput(); gl_pSerPort->printf("In RunToDaylightV2(), CheckForUserInput() returned %s\n", status? "TRUE":"FALSE"); if (!status) { return; } SpinTurn(true, 360/ RUN_TO_DAYLIGHT_ARRAY_SIZE); } |
But, this doesn’t work either, because the call to CFUI here doesn’t have anything to do with the part of CFUID that called RunToDaylightV2 – completely separate. So, I finally decided that the only way to reliably handle this (and other similar) issues is to establish a global ‘status’ variable ‘gl_AnomalyCode’ that can be set in CFUID and read anywhere. I actually had this in my previous WallE3_git project, and even had a separate ‘enum.h’ file to house the anomaly codes and other enums. I copied just the AnomalyCode section from enum.h, as shown below:
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 |
#pragma region ENUMS enum AnomalyCode { ANOMALY_NONE = 0, ANOMALY_STUCK_AHEAD, ANOMALY_STUCK_BEHIND, ANOMALY_OBSTACLE_AHEAD, ANOMALY_WALL_OFFSET_DIST_AHEAD, ANOMALY_OBSTACLE_BEHIND, ANOMALY_DEAD_BATTERY, ANOMALY_CHARGER_CONNECTED, //added 05/22/22 ANOMALY_EXCESS_STEER_VAL, //added 05/19/23 ANOMALY_IR_BEAM_AVAILABLE, //added 08/20/23 ANOMALY_MIRRORED_SFC //added 01/21/24 }; //08/23/23 unused names removed const char* AnomalyStrArray[] = { "NONE", "STUCK_AHEAD", "STUCK_BEHIND", "OBSTACLE_AHEAD", "WALL_OFFSET_DIST_AHEAD","OBSTACLE_BEHIND", "DEAD_BATTERY", "CHARGER_CONNECTED", "EXCESS_STEER_VAL", "IR_BEAM_AVAILABLE", "MIRRORED_SURFACE" };//02/08/23 added "OPEN_DOORWAY" 03/13/23 added "TRACKING_WRONG_WALL", 01/22/24 added "MIRRORED_SURFACE" uint8_t gl_AnomalyCode = ANOMALY_NONE; #pragma endregion ENUMS |
Then I added the global variable ‘uint8_t gl_AnomalyCode = ANOMALY_NONE;’ to hold the current anomaly code, and set it to ‘ANOMALY_STUCK_AHEAD’ in the ‘!STUCK_AHEAD’ CFUI section, and back to ‘ANOMALY_NONE’ in the ‘C’ CFUI section. This fixed the problem entirely (but not necessarily elegantly). RunToDaylightV2 checks the value of gl_AnomalyCode each time through the scan loop, and terminates if it isn’t ANOMALY_STUCK_AHEAD.
After sleeping on this, I started thinking that what I really want instead of (or maybe in addition to ANOMALY_CODES is a SYSTEM_STATUS enum, with STATUS_MANUAL_CONTROL set system-wide whenever the user inputs ‘C’.
enum SystemStatus { STATUS_MANUAL_CONTROL = 0, STATUS_AUTO_NAV }; SystemStatus gl_SystemStatus = SystemStatus::STATUS_AUTO_NAV;
Then, in RunToDaylightV2():
if (gl_SystemStatus == STATUS_MANUAL_CONTROL) { return; }
And in CheckForUserInput() -> ‘C’ case:
gl_SystemStatus = SystemStatus::STATUS_MANUAL_CONTROL
|
1 2 3 4 5 6 7 |
enum SystemStatus { STATUS_MANUAL_CONTROL = 0, STATUS_AUTO_NAV }; SystemStatus gl_SystemStatus = SystemStatus::STATUS_AUTO_NAV; |
And in CheckForUserInput() -> ‘C’ case:
|
1 2 3 4 5 6 7 8 9 |
case 'C': //case 0x63: // 'c' {//needed to avoid "crosses initialization of int speed" compiler error gl_SystemStatus = SystemStatus::STATUS_MANUAL_CONTROL; //10/23/26 interrupts any ongoing sequences like scans gl_pSerPort->printf("System Status changed to 'MANUAL_CONTROL: Stopping Motors\n\n"); StopBothMotors(); //09/14/26 moved above menu printout //int speed = 0; ... |
And in RunToDaylightV2():
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 |
//Step1: rotate 360deg in 10deg steps, filling arrays with the corresponding values for (size_t i = 0; i < RUN_TO_DAYLIGHT_ARRAY_SIZE; i++) { //10/23/26 added to abort scan on user 'C' input if (gl_SystemStatus == SystemStatus::STATUS_MANUAL_CONTROL) { return; } //get current environmental variables UpdateAllEnvironmentParameters(); Hdg[i] = IMUHdgValDeg; FrontD[i] = gl_FrontCm; Msec[i] = millis(); //10 / 22 / 26 added line to check for user input between steps bool status = CheckForUserInput(); gl_pSerPort->printf("In RunToDaylightV2(), CheckForUserInput() returned %s\n", status? "TRUE":"FALSE"); SpinTurn(true, 360/ RUN_TO_DAYLIGHT_ARRAY_SIZE); } |
I will keep the AnomalyCode stuff around as well, but just not for this purpose:
After making these changes, I ran the Teensy program and simulated a Pi5 command to perform a stuck scan by sending “!STUCK_SCAN’ at the PC serial port, and then sent ‘C’ after the scan actually started, with the following output:
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 31 |
11025: in CheckForUserInput got !STUCK_SCAN from Serial CheckForUserInput(!STUCK_SCAN) top of switch: buff[0] = ! 11026: 'In '!' case with buff = !STUCK_SCAN with length 11 11030: 'stuck scan' request received 16117: in CheckForUserInput got C from Serial CheckForUserInput(C) top of switch: buff[0] = C System Status changed to 'MANUAL_CONTROL: Stopping Motors ******************************************************** ****************** COMMAND KEYS ************************ ******************************************************** 0 = 180 deg CCW Turn 1 = 180 deg CW Turn A = Abort - Reboots Processor / = Forward .(dot) = Reverse * = Exit ChkForUserInput() Faster 8 Left 4 5 6 Right 2 Slower Lxx.x or Rxx.x = SpinTurn xx.x degrees Lxx.x,yy or Rxx.x,yy = SpinTurn with custom rate Tddd.d = Turn to heading ddd.d At exit from CheckForUserInput(), retval = FALSE 16171: RunToDaylightV2(): gl_SystemStatus == SystemStatus::STATUS_MANUAL_CONTROL -> Scan Aborted |
23 October 2026 Update:
So now I have the teensy RunToDaylightV2() and CheckForUserInput() code modified to handle ‘!STUCK_AHEAD’, ‘STATUS_MANUAL_CONTROL’ and ‘!STUCK_SCAN’ situations, it’s time to make the associated changes/additions to the Pi5 code.
In a ‘stuck_ahead’ situation, the teensy sends ‘!STUCK_AHEAD’ to the Pi5 via Serial1, and it is captured by the ‘telemetry_loop()’ function.
|
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 31 32 |
def telemetry_loop(): """Read lines from the Teensy and write them cleanly to the telemetry log.""" global telemetry_running, ser, latest_imu_hdg TELEMETRY_LOG.parent.mkdir(parents=True, exist_ok=True) with open(TELEMETRY_LOG, "a", buffering=1) as logf: while True: if telemetry_running and ser and ser.is_open and ser.in_waiting: try: line = ser.readline().decode(errors="ignore").rstrip() if line: logf.write(line + "\n") logf.flush() #pass any nav_seq control lines to the telemetry queue for wait_for_done() body = strip_teensy_ts(line) #added to avoid teensy timestamp in front of DONE/ACK/BUSY lines if body.startswith(("DONE ", "ACK ", "BUSY ")): teensy_events.put(body) # queue "DONE H", not "1016295 DONE H" if "IMU Heading" in body: try: hdg = float(body.split("=")[1].strip().split()[0]) t_msec = int(line.strip().split(":", 1)[0].split()[0]) set_imu_hdg(hdg, t_msec) except (ValueError, IndexError): log(f"bad IMU line: {line!r}") except Exception as e: print(f"[telemetry] {e}") time.sleep(0.02)# ---------------------------------------------------------------------- |
As shown in the code above, any line from the teensy of the form “[timestamp]: [body]” where ‘body’ is “DONE [cmd]”, “ACK [cmd]”, or “BUSY [cmd]” has the [body] extracted and placed in the ‘teensy_events’ queue. This queue is examined in ‘wait_for_done’ and if one of the above strings is present, does the right thing. This isn’t directly applicable to the ‘stuck’ situation, but something similar will be necessary. ‘telemetry_loop’ will have to recognize the anomaly flag from the teensy and pass it along to the main nav function